Showing posts with label FutureOfTransport. Show all posts

Sunday, October 11, 2026

The Robotaxi Revolution Is Coming

It’s amazing to think how far technology has come in the past 50 years. Five decades ago, accessing the internet or taking pictures from a mobile phone was unheard of. When the first cell phone launched in 1973, it weighed about two-and-a-half pounds. And the battery lasted about 20 minutes. Then, 20 years later, the DynaTAC 880X came to market, which is known as the first smartphone. It had a variety of features (what we consider apps), including an address book, calculator, calendar and email……….Continue reading….

By:  Louis Navellier

Source: InvestorPlace

.

Critics:

A robotaxi, also known as robot taxi, robo-taxi, self-driving taxi or driverless taxi, is an autonomous car (SAE automation level 4 or 5) operated for a ridesharing company. Some studies have hypothesized that robotaxis operated in an autonomous mobility on demand (AMoD) service could be one of the most rapidly adopted applications of autonomous cars at scale and a major mobility solution, especially in urban areas.

Moreover, they could have a very positive impact on road safety, traffic congestion and parking. Robotaxis could also reduce urban pollution and energy consumption, since these services will most probably use electric cars and for most of the rides, less vehicle size and range is necessary compared to individually owned vehicles. The expected reduction in number of vehicles means less embodied energy; however energy consumption for redistribution of empty vehicles must be taken into account.
Robotaxis would reduce operating costs by eliminating the need for a human driver, which might make it an affordable form of transportation and increase the popularity of transportation-as-a-service (TaaS) as opposed to individual car ownership. Such developments could lead to job destruction and new challenges concerning operator liabilities. In 2023, some robotaxis caused congestion when they blocked roads due to lost cellular connectivity, and others failed to properly yield to emergency vehicles.

As of 2023 there has been only one fatality associated with a robotaxi, a pedestrian who was hit by an Uber test vehicle in 2018. Predictions of the widespread and rapid introduction of robotaxis – by as early as 2018 – have not been realized. There are a number of trials underway in cities around the world, some of which are open to the public and generate revenue. However, as of 2021, questions have been raised as to whether the progress of self-driving technology has stalled and whether issues of social acceptance, cybersecurity and cost have been addressed.

So far all the trials have involved specially modified passenger cars with space for two or four passengers sitting in the back seats behind a partition. LIDAR, cameras and other sensors have been used on all vehicles. The cost of early vehicles was estimated in 2020 at up to US$400,000 due to custom manufacture and specialized sensors. However, the prices of some components such as LIDAR have fallen significantly.

In January 2021, Waymo stated its costs were approximately $180,000 per vehicle, and its operating cost at $0.30 per mile (~$0.19 per km), well below Uber and Lyft, but this excludes the cost of fleet technicians and customer support. Baidu announced in June 2021 it would start producing robotaxis for 500,000 yuan ($77,665) each Tesla has discussed a sub-$25,000 Tesla Robotaxi, and as of 2023 is designing an assembly line that will accommodate the vehicle.

Several companies are testing robotaxi services, especially in the United States and in China. All operate only in a geo-fenced area. Service areas for robotaxis, also known as the Objective Design Domain (ODD), are specially designated zones where robotaxis can safely provide service.[26] As of 2024, Baidu’s Apollo Go had carried the most passengers, over 6 million by April 2024.

Other providers in China include AutoX, DiDi, Pony.ai, WeRide, all operating in 10 or more cities. In the US, Waymo is the most prominent provider, operating in San Francisco, Phoenix, and Los Angeles. A 2024 study of Waymo indicated an 85% reduction in injury crashes per mile driven. Separate to these efforts have been trials of larger shared autonomous vehicles on fixed routes with designated stops, able to carry between 6 and 10 passengers. These shuttle buses operate at low speeds.

In February 2018 Arizona granted Waymo a Transportation Network Company permit. In February 2022 the California Public Utilities Commission (CPUC) issued Drivered Deployment permits to Cruise and Waymo to allow passenger service in autonomous vehicles with a safety driver present in the vehicle. These carriers must hold a valid California Department of Motor Vehicles (DMV) Deployment permit and meet the requirements of the CPUC Drivered Deployment program.

In June 2022, Cruise received approval to operate a commercial robotaxi service in San Francisco. In April 2022, China gave Baidu and Pony.ai its first permits to deploy robotaxis without safety drivers on open roads within a 23 square mile area in the Beijing Economic-Technological Development Area. In August 2023, the CPUC approved granting additional operating authority for Cruise LLC and Waymo LLC to conduct commercial passenger service using vehicles without safety drivers in San Francisco.

The approval includes the ability for both companies to charge fares for rides at any time of day. In August 2016, MIT spinoff NuTonomy was the first company to make robotaxis available to the public, starting to offer rides with a fleet of 6 modified Renault Zoes and Mitsubishi i-MiEVs in a limited area in Singapore. NuTonomy later signed three significant partnerships to develop its robotaxi service: with Grab, Uber’s rival in Southeast Asia, with Groupe PSA, which is supposed to provide the company with Peugeot 3008 SUVs and the last one with Lyft to launch a robotaxi service in Boston.

In August 2017, Cruise Automation, a self-driving startup acquired by General Motors in 2016, launched the beta version of a robotaxi service for its employees in San Francisco using a fleet of 46 Chevrolet Bolt EVs. Uber began development of self-driving vehicles in early 2015. In September 2016, the company started a trial allowing a select group of users of its ride-hailing service in Pittsburgh to order robotaxis from a fleet of 14 modified Ford Fusions. 

The test extended to San Francisco with modified Volvo XC90s before being relocated to Tempe, Arizona in February 2017. In March 2017, one of Uber’s robotaxis crashed in self-driving mode in Arizona, which led the company to suspend its tests before resuming them a few days later. In March 2018, Uber paused self-driving vehicle testing after the death of Elaine Herzberg in Tempe, Arizona, a pedestrian struck by an Uber vehicle while attempting to cross the street, while the onboard engineer was watching videos. Uber settled with the victim’s family.

In January 2021, Uber sold its self driving division, Advanced Technologies Group (ATG), to Aurora Innovation for $4 billion while also investing $400 million into Aurora for a 26% ownership stake.

The robotaxi is finally here: this is the Tesla Cybercab, yours for $30k TopGear 11:33 

.

RobotaxiRevolution ,FutureOfTransport ,AutonomousVehicles ,SmartMobility ,RideHailing ,TechInnovation ,UrbanTransport ,SelfDrivingCars ,SustainableTravel ,MobilitySolutions ,TransportInnovation ,SharedMobility ,SmartCities ,AIinTransport ,Robotaxi ,UrbanInnovation,FutureOfDriving ,TransportationTech ,MobilityRevolution ,TechForGood

Wednesday, September 23, 2026

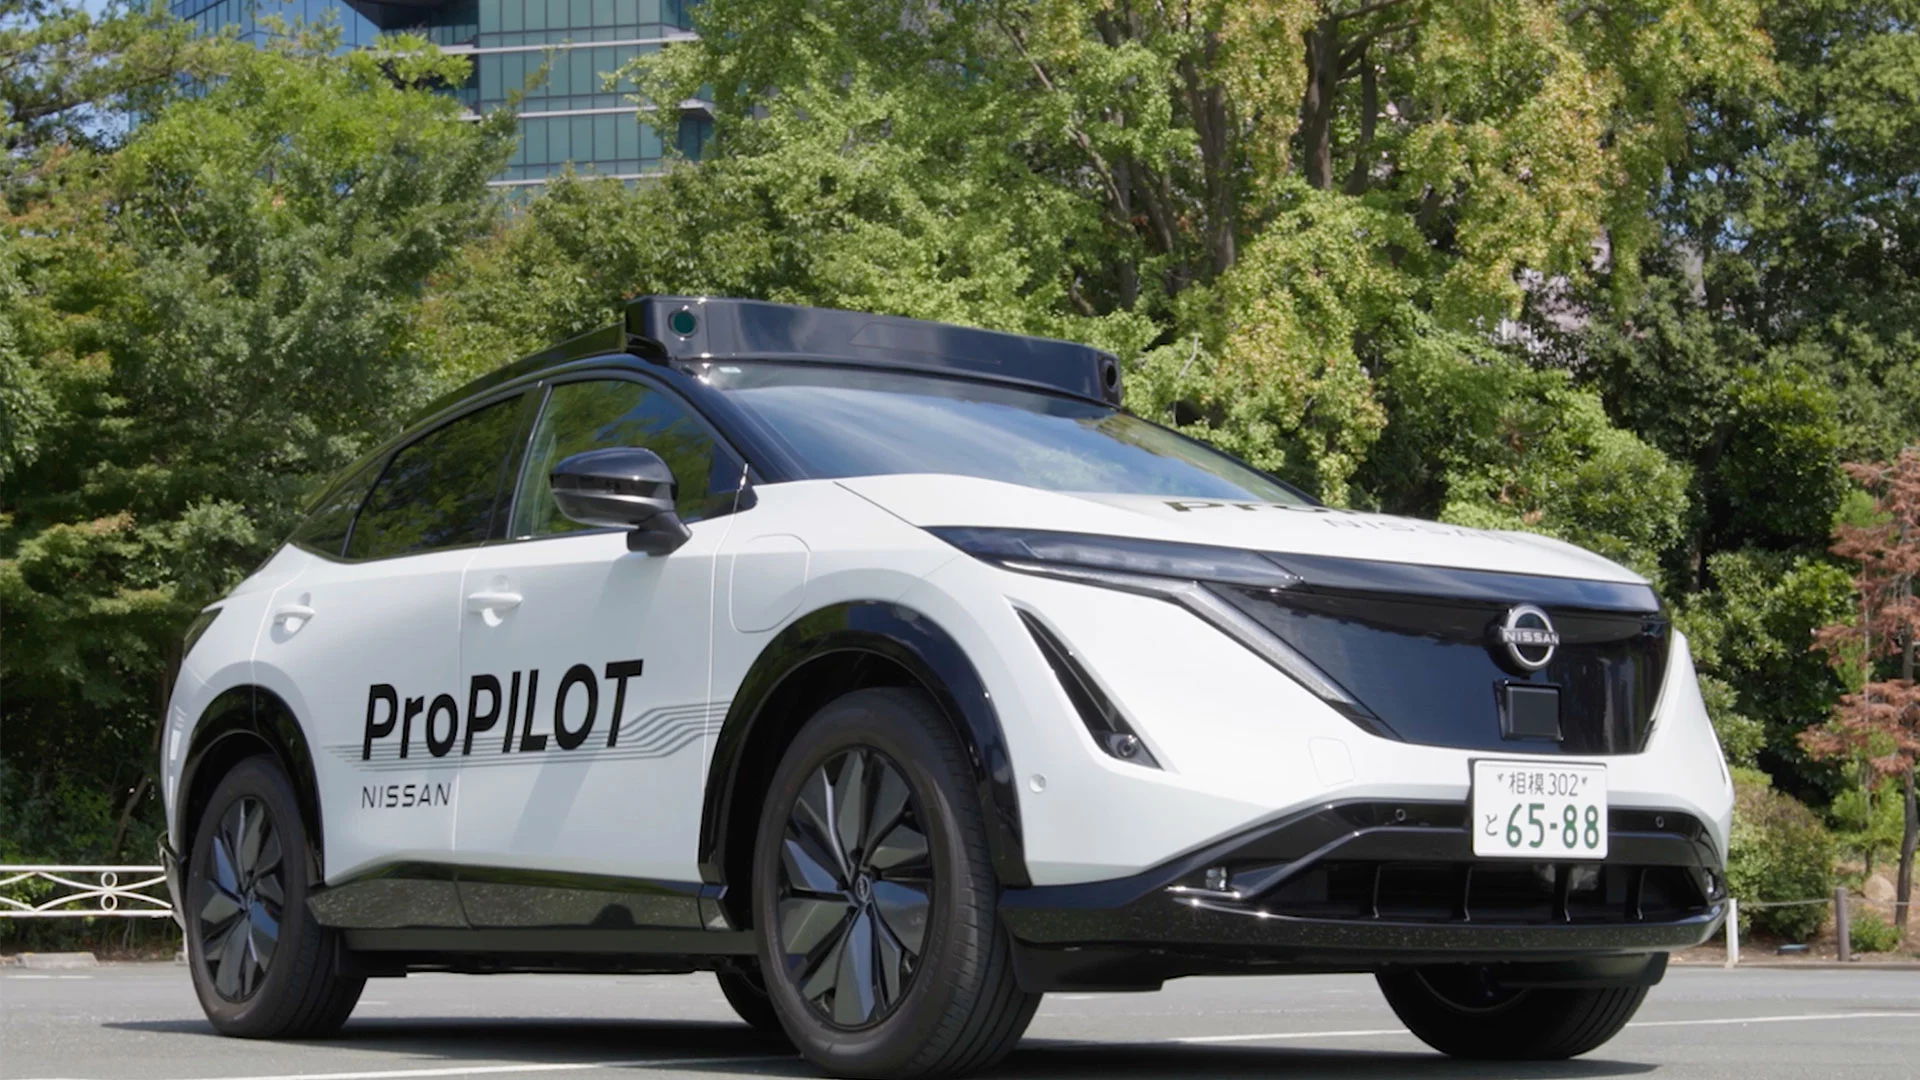
Nissan’s Latest Comeback Attempt: Self-Driving Vehicles Equipped With Wayve’s Technology

Nissan Motor Co. via AP

Japanese automaker Nissan is developing vehicles with self-driving technology as it works to turn around its struggling auto business. In a recent demonstration of the technology developed by British company Wayve, a Nissan Ariya sedan outfitted with 11 cameras, five radars and a next-generation sensor called LiDAR maneuvered its way through downtown Tokyo, braking for red lights as well as pedestrians and other cars at intersections……..Continue reading….

By: Yuri Kageyama

Source:  Fast Company

.

Critics:

The Union of Concerned Scientists defined self-driving as “cars or trucks in which human drivers are never required to take control to safely operate the vehicle. Also known as autonomous or ‘driverless’ cars, they combine sensors and software to control, navigate, and drive the vehicle.” The British Automated and Electric Vehicles Act 2018 law defines a vehicle as “driving itself” if the vehicle is “not being controlled, and does not need to be monitored, by an individual”.

Another British government definition stated, “Self-driving vehicles are vehicles that can safely and lawfully drive themselves”. Operational design domain (ODD) is a term for a particular operating context for an automated system, often used in the field of autonomous vehicles. The context is defined by a set of conditions, including environmental, geographical, time of day, and other conditions. For vehicles, traffic and roadway characteristics are included.

Manufacturers use ODD to indicate where/how their product operates safely. A given system may operate differently according to the immediate ODD. The concept presumes that automated systems have limitations. Relating system function to the ODD it supports is important for developers and regulators to establish and communicate safe operating conditions. Systems should operate within those limitations. Some systems recognize the ODD and modify their behavior accordingly.

For example, an autonomous car might recognize that traffic is heavy and disable its automated lane change feature. Vendors have taken a variety of approaches to the self-driving problem. Tesla’s approach is to allow their “full self-driving” (FSD) system to be used in all ODDs as a Level 2 (hands/on, eyes/on) ADAS. Waymo picked specific ODDs (city streets in Phoenix and San Francisco) for their Level 5 robotaxi service.

Mercedes Benz offers Level 3 service in Las Vegas in highway traffic jams at speeds up to 40 miles per hour (64 km/h) Mobileye’s SuperVision system offers hands-off/eyes-on driving on all road types at speeds up to 130 kilometres per hour (81 mph). GM’s hands-free Super Cruise operates on specific roads in specific conditions, stopping or returning control to the driver when ODD changes. In 2024 the company announced plans to expand road coverage from 400,000 miles to 750,000 miles.

Ford’s BlueCruise hands-off system operates on 130,000 miles of US divided highways. The perception system processes visual and audio data from outside and inside the car to create a local model of the vehicle, the road, traffic, traffic controls and other observable objects, and their relative motion. The control system then takes actions to move the vehicle, considering the local model, road map, and driving regulations. Several classifications have been proposed to describe ADAS technology. One proposal is to adopt these categories: navigation, path planning, perception, and car control.

Navigation involves the use of maps to define a path between origin and destination. Hybrid navigation is the use of multiple navigation systems. Some systems use basic maps, relying on perception to deal with anomalies. Such a map understands which roads lead to which others, whether a road is a freeway, a highway, are one-way, etc. Other systems require highly detailed maps, including lane maps, obstacles, traffic controls, etc.

ACs need to be able to perceive the world around them. Supporting technologies include combinations of cameras, LiDAR, radar, audio, and ultrasound, GPS, and inertial measurement. Deep neural networks are used to analyse inputs from these sensors to detect and identify objects and their trajectories. Some systems use Bayesian simultaneous localization and mapping (SLAM) algorithms. Another technique is detection and tracking of other moving objects (DATMO), used to handle potential obstacles. Other systems use roadside .

real-time locating system (RTLS) technologies to aid localization. Tesla’s “vision only” system uses eight cameras, without LIDAR or radar, to create its bird’s-eye view of the environment. Path planning finds a sequence of segments that a vehicle can use to move from origin to destination. Techniques used for path planning include graph-based search and variational-based optimization techniques. Graph-based techniques can make harder decisions such as how to pass another vehicle/obstacle.

Variational-based optimization techniques require more stringent restrictions on the vehicle’s path to prevent collisions. The large scale path of the vehicle can be determined by using a voronoi diagram, an occupancy grid mapping, or a driving corridor algorithm. The latter allows the vehicle to locate and drive within open space that is bounded by lanes or barriers. Maps are necessary for navigation.

Map sophistication varies from simple graphs that show which roads connect to each other, with details such as one-way vs two-way, to those that are highly detailed, with information about lanes, traffic controls, roadworks, and more. Researchers at the MITComputer Science and Artificial Intelligence Laboratory (CSAIL) developed a system called MapLite, which allows self-driving cars to drive with simple maps.

The system combines the GPS position of the vehicle, a “sparse topological map” such as OpenStreetMap (which has only 2D road features), with sensors that observe road conditions. One issue with highly-detailed maps is updating them as the world changes. Vehicles that can operate with less-detailed maps do not require frequent updates or geo-fencing. Sensors are necessary for the vehicle to properly respond to the driving environment.

Sensor types include cameras, LiDAR, ultrasound, and radar. Control systems typically combine data from multiple sensors. Multiple sensors can provide a more complete view of the surroundings and can be used to cross-check each other to correct errors. For example, radar can image a scene in, e.g., a nighttime snowstorm, that defeats cameras and LiDAR, albeit at reduced precision.

After experimenting with radar and ultrasound, Tesla adopted a vision-only approach, asserting that humans drive using only vision, and that cars should be able to do the same, while citing the lower cost of cameras versus other sensor types. By contrast, Waymo makes use of the higher resolution of LiDAR sensors and cites the declining cost of that technology.

CES2025 | John Deere autonomous mower promises a perfect cut, every time Electrek 6d
.
SelfDrivingVehicles ,AutonomousCars ,FutureOfTransport ,TechInnovation ,SmartDriving ,VehicleAutomation ,MobilityRevolution #DriverlessTechnology ,AutomotiveFuture ,SustainableTransport ,AIinDriving ,TransportationTrends ,InnovativeVehicles ,MixedTrafficking ,SelfDrivingTech ,SafetyFirst ,,UrbanMobility ,SmartCities ,TransportationSolutions

Leave a Reply

Claude Business Brain 47 Done-For-You Claude Projects + Unrestricted PLR

What if you could stop writing the same business instructions into Claude every single day? Imagine having ready-made AI workflows for clien...